
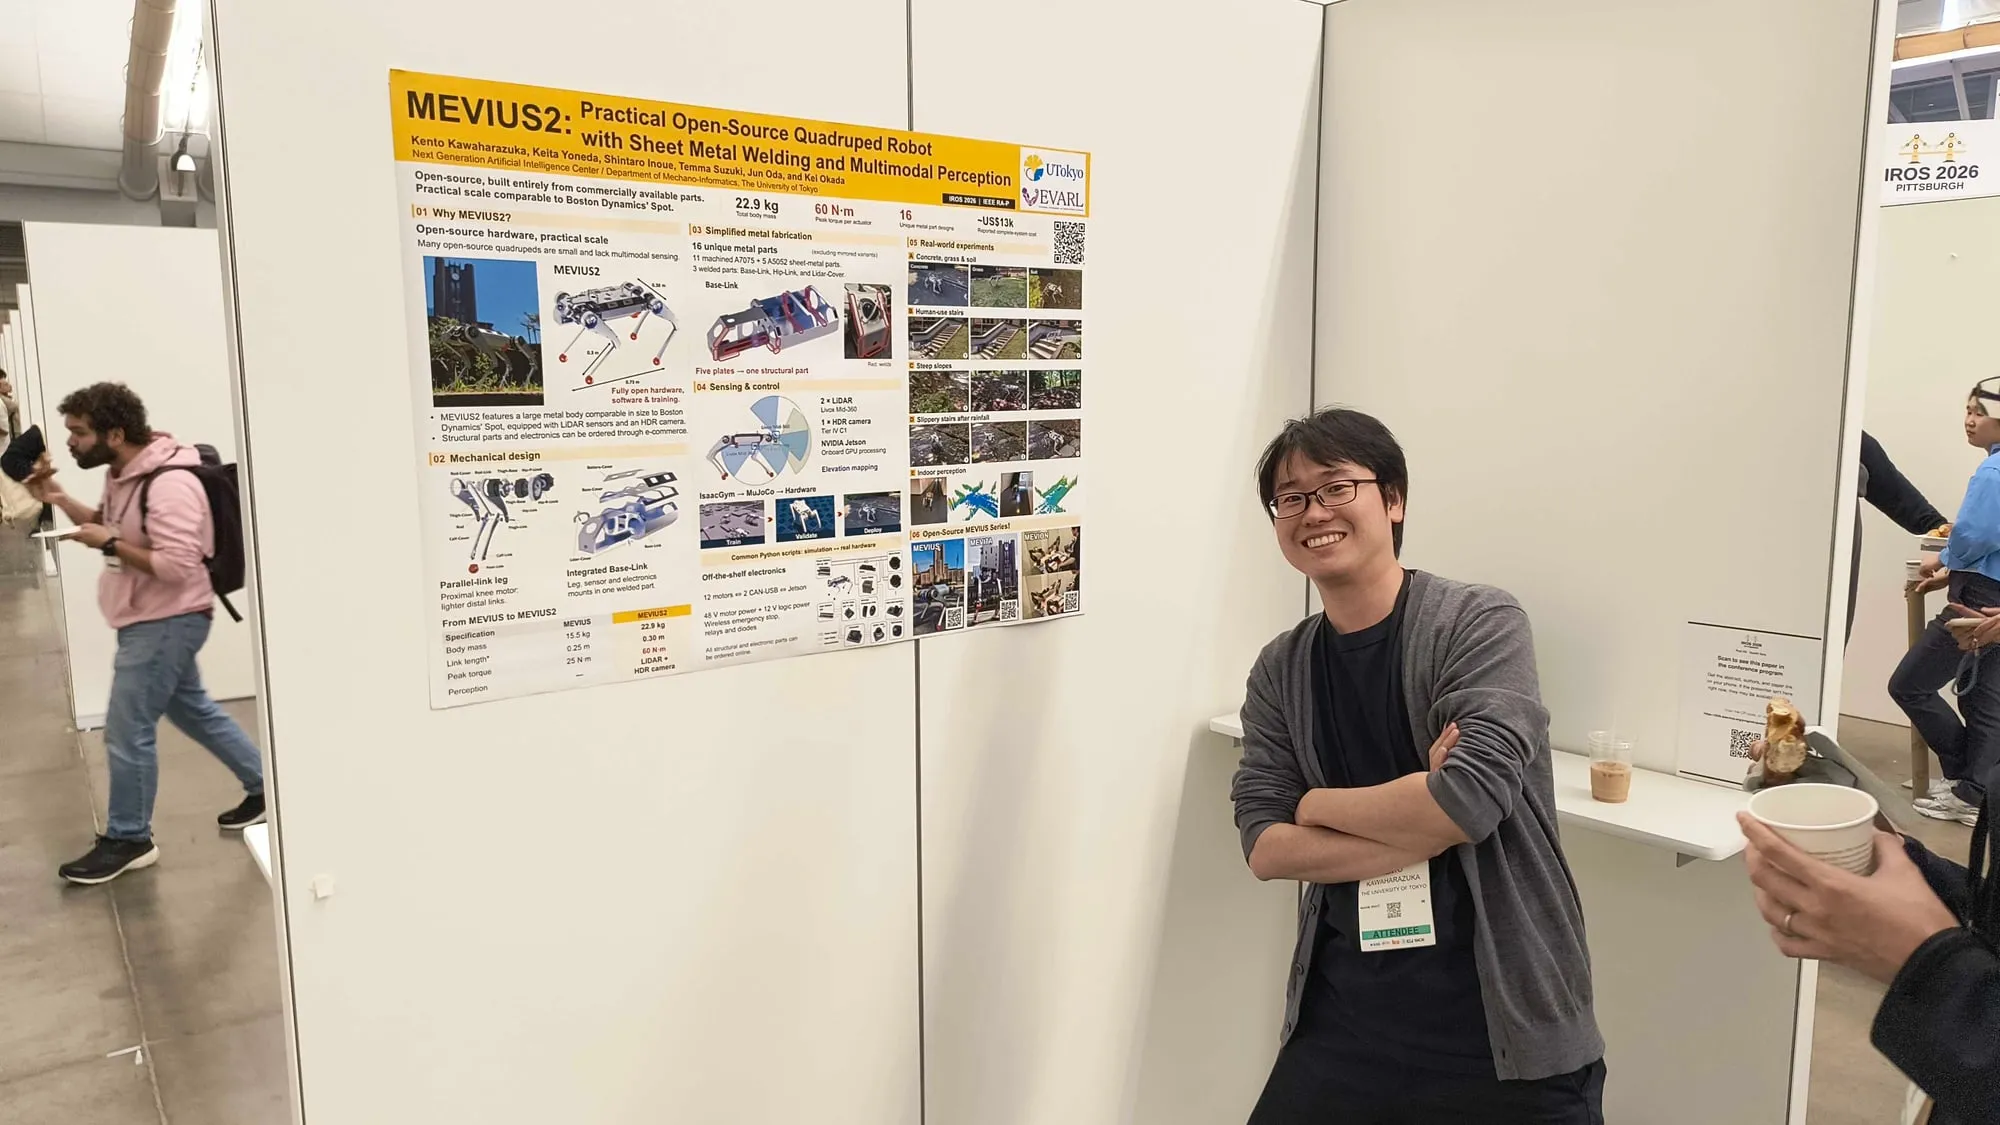
Project Manager Kawaharazuka explaining MEVIUS2
Young principal investigators and research collaborators of the MIRAI Humanoid Project · Moonshot Goal 3 took an active part in IROS2026, one of the world’s largest international robotics conferences, held in Pittsburgh, USA, from September 27 to October 1, 2026.
Nine project members contributed as authors to 22 paper presentations submitted before the project began and accepted through peer review. During the conference, they presented their work in many poster sessions.
Project Manager Kento Kawaharazuka, PIs Asako Kanezaki and Taisuke Kobayashi, and research collaborator Satoshi Yamamori (Kyoto University) also chaired or co-chaired a total of eight sessions. They supported research presentations and discussions across mechanical design, locomotion, navigation, SLAM, planning and control, and robot policy learning.
Presented Papers Co-Authored by Project Members
Papers are listed by author below. One paper appears under two project members, giving 23 entries and 22 distinct papers. These papers were submitted before this project began and are therefore included here for reference, rather than counted as outcomes of this project.
Kento Kawaharazuka (Project Manager)
-
Neural Introspection Gating for Adaptive KV-Cache Reuse in Vision-Language-Action Models
Zhijie Wu, Kento Kawaharazuka, Kei Okada
September 28 (Monday) | Perception and Learning for Robot Manipulation
IROS Program / Paper PDF / arXiv / Project Page -
Robust Brachiation on a Life-Sized Dual-Arm Robot Using Waypoint-Guided Reinforcement Learning
Ayumu Iwata, Kento Kawaharazuka, Keita Yoneda, Takahiro Hattori, Kei Okada
September 28 (Monday) | IROS Best Entertainment and Amusement Paper Award
IROS Program / Paper PDF / arXiv / Project Page -
LunaDrive: A Delay-Compensated High-Voltage GaN FET-Based Motor Driver for Dynamic Robots with Flat BLDC Motors
Sota Yuzaki, Temma Suzuki, Hiromi Tada, Masanori Konishi, Kento Kawaharazuka, Kei Okada
September 28 (Monday) | Inventive Hardware for New Robot Mechanisms
IROS Program / Paper PDF / arXiv / Project Page -
EFGCL: Dynamic Motion Acquisition through Spotting-Inspired External Force Guided Curriculum Learning
Keita Yoneda, Kento Kawaharazuka, Kei Okada
September 29 (Tuesday) | Efficient and Continual Learning of Robot Skills
IROS Program / Paper PDF / arXiv / Project Page -
Detachable Wire Drive: Reconfigurable Robot Architecture with Shared Actuators
Takahiro Hattori, Kento Kawaharazuka, Kei Okada
September 29 (Tuesday) | Building Adaptability Into Robot Joints
IROS Program / Paper PDF / arXiv / Project Page -
VLAff: Vision-Language-Affordance Model for Unified Actionable Affordances
Jihoon Oh, Kento Kawaharazuka, Kei Okada
September 29 (Tuesday) | New Representations for Vision-Language-Action Robots
IROS Program / Paper PDF / arXiv / Project Page -
MEVIUS2: Practical Open-Source Quadruped Robot with Sheet Metal Welding and Multimodal Perception
Kento Kawaharazuka, Keita Yoneda, Shintaro Inoue, Temma Suzuki, Jun Oda, Kei Okada
September 30 (Wednesday) | New Mechanical Designs for Legged and Wheeled Robots
IROS Program / Paper PDF / arXiv / Project Page -
WARL: Wrench-Augmented Reinforcement Learning for Task-Agnostic Learning in Legged Robots
Keita Yoneda, Kento Kawaharazuka, Kei Okada
September 30 (Wednesday) | Smarter Training Strategies for Legged Robot Policies
IROS Program / Paper PDF / arXiv / Project Page -
Design of a Biomimetic Joint-Covering Skin with Tissue-Like Structure to Enhance Proprioception in a Musculoskeletal Humanoid
Akihiro Miki, Shun Hasegawa, Yoshimoto Ribayashi, Kento Kawaharazuka, Kei Okada
September 30 (Wednesday) | Estimating Physical Properties Through Diverse Senses
IROS Program / Paper PDF / arXiv / Project Page
Masaki Murooka (PI)
- Self-Augmented Robot Trajectory: Efficient Imitation Learning Via Safe Self-Augmentation with Demonstrator-Annotated Precision
Hanbit Oh, Masaki Murooka, Tomohiro Motoda, Ryoichi Nakajo, Yukiyasu Domae
September 28 (Monday) | Data-Efficient Imitation Learning
IROS Program / Paper PDF / arXiv / Project Page
Shuhei Kurita (PI)
-
HiFlow: Tokenization-Free Scale-Wise Autoregressive Policy Learning Via Flow Matching
Daichi Yashima, Koki Seno, Shuhei Kurita, Yusuke Oda, Komei Sugiura
September 28 (Monday) | Perception and Learning for Robot Manipulation
IROS Program / Paper PDF / arXiv / Project Page -
PhysQuantAgent: An Inference Pipeline of Mass Estimation for Vision-Language Models
Hisayuki Yokomizo, Taiki Miyanishi, Gang Yan, Shuhei Kurita, Nakamasa Inoue, Yusuke Iwasawa
September 29 (Tuesday) | New Sensors and Data for Manipulation
IROS Program / Paper PDF / arXiv
Asako Kanezaki (PI)
- EED: Embodied Environment Description through Robotic Visual Exploration
Kohei Matsumoto, Asako Kanezaki
September 28 (Monday) | Rethinking Scene Representations for Navigation
IROS Program
Satoshi Yagi (PI)
- Automatic Terrain Curriculum Generation Via Optimal Transport for Multi-DoF Rover Robot Locomotion
Kenjiro Minamikawa, Kaito Suginaka, Satoshi Yamamori, Satoshi Yagi, Kazuya Yoshida, Jun Morimoto
September 28 (Monday) | Scaling Up Robot Policy Learning
IROS Program
Taisuke Kobayashi (PI)
-
Distance Field Driven Reinforcement Learning for Reactive and Robust Collision Avoidance
Taiga Ikeshima, Sheila Sutjipto, Lan Wu, Francisco J Naranjo-Campos, Taiki Ishigaki, Taisuke Kobayashi, Teresa A. Vidal-Calleja, Eiichi Yoshida
September 28 (Monday) | Safe and Predictive Robot Navigation
IROS Program -
CubeDAgger: Interactive Imitation Learning for Dynamic Systems with Efficient yet Low-Risk Interaction
Taisuke Kobayashi
September 29 (Tuesday) | Learning-Based Strategies for Robot Planning and Control
IROS Program / Paper PDF / arXiv
Kenji Koide (Research Collaborator)
-
KING: Embodiment-Aware Kinematic Graph Neural Network for Unified Motion Representation of Legged and Wheeled Robots
Taku Okawara, Aoki Takanose, Kenji Koide, Shuji Oishi, Masashi Yokozuka
September 28 (Monday) | New Angles on Localization and Mapping
IROS Program / Paper PDF / arXiv / Project Page -
Image-To-Point Cloud Registration Made Easy with Rectified Flow-Based LiDAR Upsampling
Reon Tabata, Kenji Koide, Shuji Oishi, Masashi Yokozuka, Taku Okawara, Aoki Takanose, Jun Miura
September 28 (Monday) | Vision Systems for Robotics and Industrial Applications
IROS Program / Paper PDF / arXiv / Project Page -
MirrorDrift: Actuated Mirror-Based Attacks on LiDAR SLAM
Rokuto Nagata, Kenji Koide, Kazuma Ikeda, Ozora Sako, Shion Horie, Kentaro Yoshioka
September 29 (Tuesday) | Efficient and Secure SLAM at the Edge
IROS Program / Paper PDF / arXiv -
D-SLAMSpoof: An Environment-Agnostic LiDAR Spoofing Attack Using Dynamic Point Cloud Injection
Rokuto Nagata, Kenji Koide, Kazuma Ikeda, Ozora Sako, Kentaro Yoshioka
September 29 (Tuesday) | Robust Point Cloud Registration and Odometry
IROS Program / Paper PDF / arXiv -
Tightly Coupled LiDAR-IMU Odometry with Online Adaptation of a Learning-Based IMU Motion Model
Kazushi Fujimoto, Kenji Koide, Taku Okawara, Aoki Takanose, Shuji Oishi, Masashi Yokozuka, Nobuhiko Nishio
September 30 (Wednesday) | New Methods for Spatial Perception and Localization
IROS Program / Paper PDF
Keisuke Shirai (Research Collaborator)
- Grounded Vision-Language Interpreter for Long-Horizon Bimanual Task and Motion Planning
Jeremy Siburian, Keisuke Shirai, Cristian Camilo Beltran-Hernandez, Masashi Hamaya, Michael Görner, Atsushi Hashimoto
September 28 (Monday) | Constraint-Guided Reasoning for Long-Horizon Manipulation
IROS Program / Paper PDF / arXiv / Project Page
Satoshi Yamamori (Research Collaborator)
- Automatic Terrain Curriculum Generation Via Optimal Transport for Multi-DoF Rover Robot Locomotion
Kenjiro Minamikawa, Kaito Suginaka, Satoshi Yamamori, Satoshi Yagi, Kazuya Yoshida, Jun Morimoto
September 28 (Monday) | Scaling Up Robot Policy Learning
IROS Program
Sessions Chaired or Co-Chaired by Project Members
Kento Kawaharazuka (Project Manager)
Served as chair and co-chair for the following two sessions on September 30 (Wednesday), afternoon.
- New Mechanical Designs for Legged and Wheeled Robots
- Smarter Training Strategies for Legged Robot Policies
Asako Kanezaki (PI)
Served as chair and co-chair for the following two sessions on September 28 (Monday), afternoon.
Taisuke Kobayashi (PI)
Served as chair and co-chair for the following two sessions on September 29 (Tuesday), morning.
Satoshi Yamamori (Research Collaborator)
Served as chair and co-chair for the following two sessions on September 28 (Monday), morning.
Related link: IROS2026 Official Program